• Global CNC market projected to reach $128B by 2028 • New EU trade regulations for precision tooling components • Aerospace deman
NYSE: CNC +1.2%LME: STEEL -0.4%
How to Integrate Warehouse Palletizing Robots with Minimal Downtime
How to Integrate Warehouse Palletizing Robots with Minimal Downtime
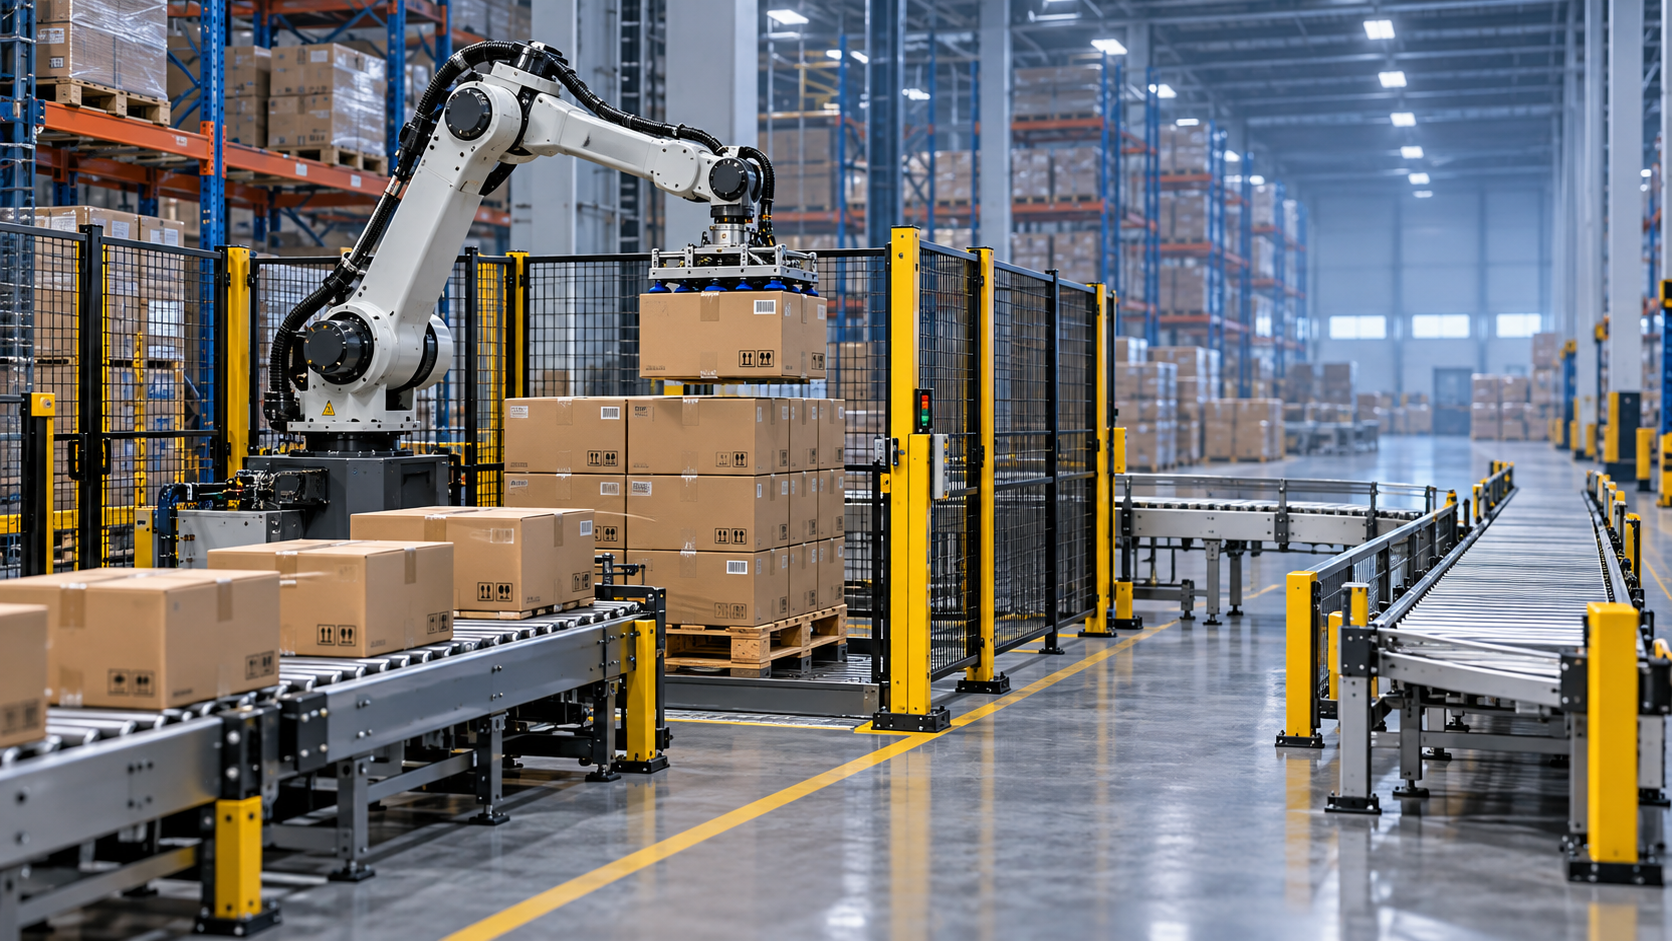
Integrating warehouse palletizing robots should improve throughput—not derail shipping schedules. The challenge is coordinating equipment selection, conveyor interfaces, control systems, and safety validation while keeping daily operations running. Industrial Robotics for Warehouse Automation requires more than installing a robot: it demands a phased deployment plan, clear acceptance criteria, and a tested fallback process.
The practical goal is not an installation with no interruption whatsoever. It is to move uncertainty out of the shutdown window. Layout decisions, product trials, software testing, and operator preparation should happen before the existing palletizing process is disconnected.
Define the operating envelope before choosing the robot
A robot’s advertised cycle rate tells you little about whether the complete cell can keep shipping moving. Actual output depends on carton arrival patterns, pick orientation, pallet changes, slip-sheet handling, upstream interruptions, and recovery from faults. Start with the production conditions the cell must handle—not a preferred robot model.
Collect representative operating data across normal shifts, peak periods, and product changeovers. Average throughput can hide short bursts that overwhelm an otherwise adequate system. Record product dimensions, weight ranges, packaging condition, pallet specifications, stacking patterns, and the frequency of exceptions.
In precision manufacturing, the load may be a carton of machined components, a reusable tote, or a fixture-supported assembly. Dense metal parts can shift inside packaging, while oily surfaces or porous cartons can undermine gripping assumptions. Verify the packaged load’s center of gravity and stability rather than relying only on its nominal weight.
- Check robot payload with the end-of-arm tooling, adapters, hoses, and carried product included.
- Validate reach at the most difficult pick and place positions, including the highest pallet layer.
- Confirm that conveyors, pallet dispensers, wrapping equipment, and takeaway routes can support the required flow.
- Identify products that need an alternate process instead of forcing every exception through the initial deployment.
For CNC plants, this assessment should include upstream packaging and inspection. Automating palletizing will not remove delays caused by inconsistent tote loading or missing release information. It may simply make those delays more visible.
Design around the cutover, not just the finished layout
A layout can work perfectly after commissioning and still be difficult to install without disrupting operations. Review two separate conditions: how the completed cell will operate, and how equipment will reach its final position while the warehouse remains active.
Check unloading access, rigging routes, floor condition, anchoring requirements, electrical capacity, compressed-air quality, network connections, and maintenance clearances. Floor loading and anchor suitability need confirmation against the equipment design and site conditions. Discovering an unsuitable slab during installation can invalidate the shutdown plan.
Where space permits, build and test the new cell beside the existing process. Install utilities and offline conveyor sections in advance, then reserve the shutdown for final connections and validation. A temporary bypass may keep selected products moving, but only if its routing, staffing, guarding, and material-handling risks have been assessed.
The layout review should show normal product flow, installation access, and the fallback route together. This exposes conflicts that a robot reach study alone will miss, such as full pallets blocking emergency access or forklifts crossing an operator replenishment point.
Make interface ownership explicit
Mechanical installation is visible. Interface problems are easier to overlook until several machines must run together. A conveyor may report “ready” while its downstream zone is occupied; a warehouse system may assign a pallet before the correct product recipe is active.
Create an interface control document covering signals, operating states, timing assumptions, fault responses, and recovery responsibilities. Assign one owner to each interface, even when several suppliers contribute hardware or software.
At minimum, define how the system handles product available, pick complete, pallet present, pallet complete, downstream blocked, recipe mismatch, and communications loss. Specify whether each signal is a maintained state or an acknowledged event. Otherwise, a brief interruption can produce duplicate commands or leave equipment waiting indefinitely.
Keep real-time machine coordination within the appropriate control architecture. Warehouse management and execution systems can supply order information, product identity, and pallet records, but should not be assumed suitable for time-critical motion coordination. Safety functions need their own validated architecture rather than dependence on ordinary business-system messaging.
Recovery logic deserves particular attention. If power fails halfway through a layer, what confirms which cartons remain on the pallet? Define a reconciliation procedure using reliable retained state, sensing, operator confirmation, or a combination appropriate to the application. Blindly restarting a sequence is not a recovery strategy.
Use factory testing to eliminate site debugging
Simulation helps identify reach limitations, collisions, and sequence constraints. It cannot prove that a vacuum gripper will reliably lift a dusty carton or that a loaded tote will settle correctly on an uneven pallet. Physical trials should use representative products, packaging, pallets, and tooling.
Agree on factory acceptance testing before equipment assembly is complete. The test plan should define the product mix, operating duration, throughput measurement boundary, permitted interventions, pallet-quality criteria, and fault scenarios. A short demonstration with one easy product is not evidence of production readiness.
Measure complete-cell performance, including normal pallet exchanges and required auxiliary operations. Separate planned external interruptions from equipment faults so the results remain interpretable. Acceptance thresholds should come from the site’s production requirements, not a generic benchmark.
- Product handling: Test difficult packaging, extreme approved loads, and the least accessible pallet positions.
- Exceptions: Challenge missing products, failed picks, absent pallets, blocked discharge, and incorrect recipe selection.
- Restart: Verify controlled recovery after approved stop and power-loss test scenarios.
- Handover: Check backups, software versions, drawings, spare-parts information, and operator instructions against the delivered configuration.
Record unresolved issues with an owner and closure date. Distinguish defects that prevent shipment or safe operation from minor documentation corrections. That distinction prevents schedule pressure from turning an unfinished system into a site commissioning problem.
Protect the shutdown window with decision gates
The cutover plan should identify dependencies, responsible people, expected durations, and the latest point at which rollback remains practical. “Install over the weekend” is a calendar entry, not an execution plan.
Before shutdown approval, confirm equipment delivery, contractor availability, permits, isolation arrangements, required spares, and successful completion of prerequisite tests. Back up affected control systems and document the existing configuration. Preserve equipment needed for fallback until the new process has passed its release criteria.
A useful sequence is mechanical completion, electrical verification, safety validation, dry cycling, product trials, and controlled production release. Some activities can run in parallel, but their dependencies still matter. A motion test cannot substitute for validation of the protective measures required for production operation.
Set a specific go/no-go checkpoint before the remaining recovery window becomes too short. The decision should consider unresolved faults, demonstrated output, safe operation, and the time needed to restore the fallback process—not just whether the robot has moved successfully.
Buffer stock can reduce shipping exposure, but it needs calculation. Relate it to demand during the planned interruption and a credible recovery allowance, then check storage space, product traceability, and downstream capacity. Extra inventory is not useful if it blocks the installation area.
Treat safety and recovery as part of commissioning
Risk assessment must cover the complete application: robot, gripper, conveyors, pallet movement, stored energy, falling loads, and human access. A robot marketed for collaborative use does not automatically make a palletizing application safe without guarding. The load, tooling, speed, and surrounding equipment affect that judgment.
Determine applicable machinery, electrical, robot-system, and workplace requirements for the destination market with qualified specialists. Validate protective devices and safety-related controls against the assessed risks. Supplier documentation is an input to this work, not a substitute for application-level verification.
Pay particular attention to routine interventions: removing damaged cartons, replenishing slip sheets, clearing conveyor jams, and correcting incomplete pallets. If these tasks are awkward, operators may face pressure to improvise. Provide defined access, isolation, and restart procedures before production release.
Train operators on normal use and recognizable faults; train maintenance personnel on diagnostics, approved recovery, and backup restoration. Alarm messages should explain the condition and the permitted next action rather than displaying only an internal fault code.
Ramp up by evidence, not by installation completion
Begin with a controlled product family and staffed support, then expand as handling quality and recovery performance are demonstrated. Test demanding approved products before unrestricted release; do not leave them until the commissioning team has departed.
Track completed pallets, unplanned stops, manual interventions, recovery time, product damage, and stacking defects. Review losses by cause rather than combining every interruption into one availability figure. A reliable robot can still sit inside an unreliable process.
For manufacturers extending automation from CNC machining into warehouse handling, the next useful deliverable is a shared readiness review: operating envelope, interface ownership, acceptance tests, safety actions, cutover schedule, and rollback criteria. If those items are unresolved, protect the shipping schedule by resolving them before booking the shutdown.
NEXT ARTICLE
Recommended for You
![]() White House Section 232 Ruling: No New Machine Tool or Robot Tariffs, Calls for TalksManufacturing Policy Research Center
 How to Integrate Warehouse Palletizing Robots with Minimal DowntimeMachine Tool Industry Editorial Team
![]() AI Investment Lifts US September Equipment Demand; Core Capital Goods Orders Rise 0.5%Manufacturing Market Research Center
 Why Heavy Machinery Shafts Fail Under Cyclic Loads and How to Prevent ItCNC Machining Technology Center
![]() JTEKT Introduces G5 Series Large CNC Cylindrical Grinder, Sales Begin October 26, 2026Machine Tool Industry Editorial Team
 Shaft Parts for Heavy Machinery: Selecting Materials for High Shock LoadsCNC Machining Technology Center

Aris Katos
Future of Carbide Coatings
15+ years in precision manufacturing systems. Specialized in high-speed milling and aerospace grade alloy processing.
▶
How to Integrate Warehouse Palletizing Robots with Minimal DowntimeMachine Tool Industry Editorial Team▶
FANUC Invests $18 Million in Largest U.S. Corporate Automation Training CenterMachine Tool Industry Editorial Team▶
Automated Production Machining: Which Parts and Batch Sizes Are a Good Fit?Machine Tool Industry Editorial Team▶
Choosing Automated Machine Tools for High-Mix, Low-Volume ProductionMachine Tool Industry Editorial Team▶
Choosing Industrial Robots for Warehouse Picking and PalletizingMachine Tool Industry Editorial Team
▶
Mastering 5-Axis Workholding Strategies
Join our technical panel on Nov 15th to learn about reducing vibrations in thin-wall components.
Providing you with integrated sanding solutions
Before-sales and after-sales services
Comprehensive technical support